You don’t need an anniversary, an apology, or a suspiciously expensive restaurant reservation to give someone a flower. Sometimes “I thought of you” is quite enough.
And sometimes the flower can be made of mathematics.
This digital rose has no delivery slot, requires no watering, and will not quietly turn into a small composting experiment on the kitchen table. You can rotate it, reshape it, and watch its petals change. Try doing that with a supermarket bouquet without attracting attention.
There is even a modest sustainability argument: no cut stems, no wrapping, and no emergency purchase of a vase. The screen still needs electricity, of course. Even romance has system requirements.
This is not a proposal to replace gardens with graphics cards. Real flowers remain exceptionally good at being flowers. But a small digital gesture can still say something real: you matter to me, and here is a beautiful thing I wanted you to have.
So send this rose to your favourite human. Tell them it reminded you of them.
You may want to leave out the part about exponential decay.
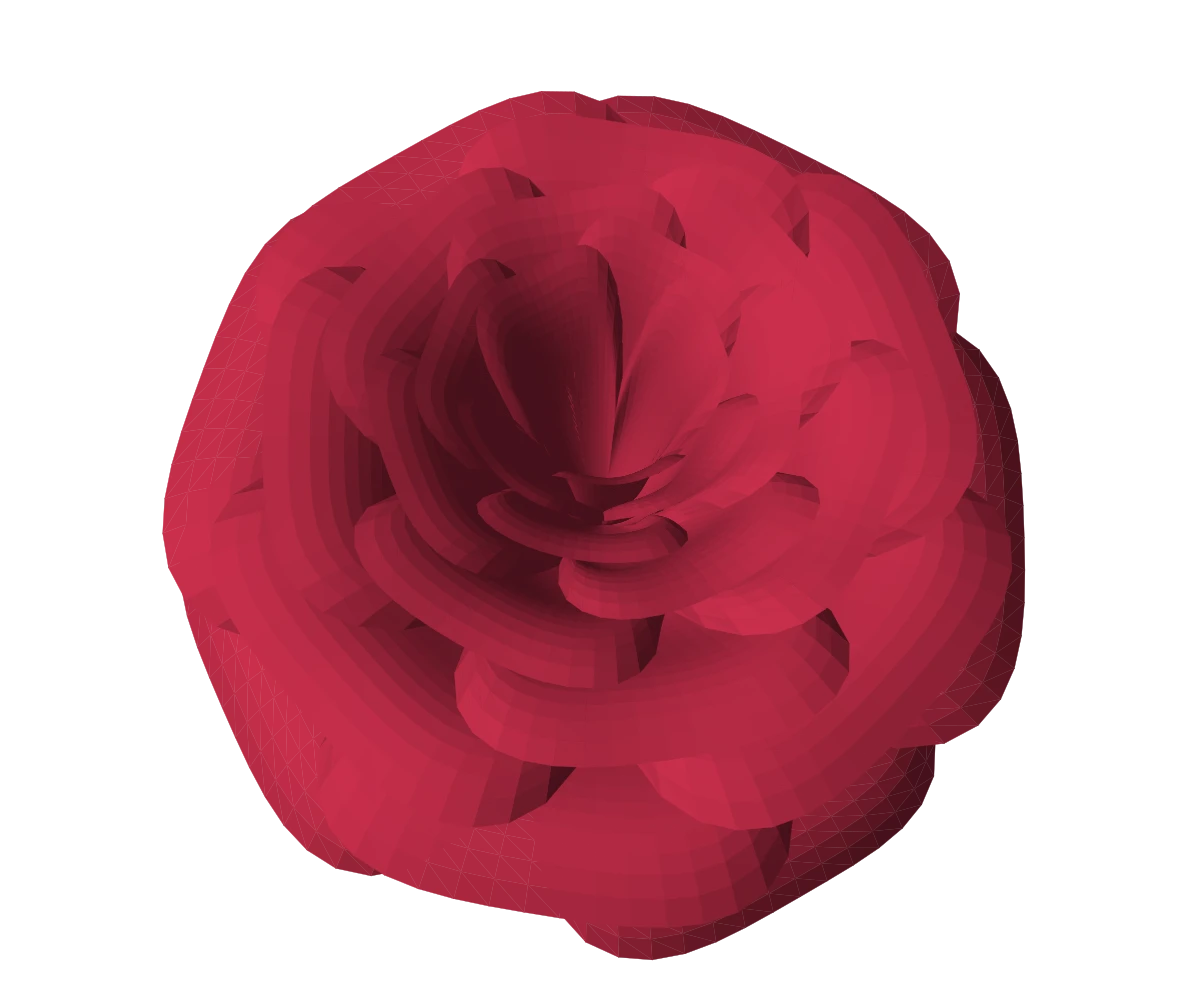
Drag to rotate. Pinch to zoom. Use Play to animate the shape.
Static preview. Interactive controls load when available.
The mathematics
The original rose uses k = 8 and 8.5 windings. The controls vary these parameters; all remaining coefficients stay fixed.
Source: Paul Nylander, “Rose-Shaped Parametric Surface” (2006).
No comments yet